RM-GB-11
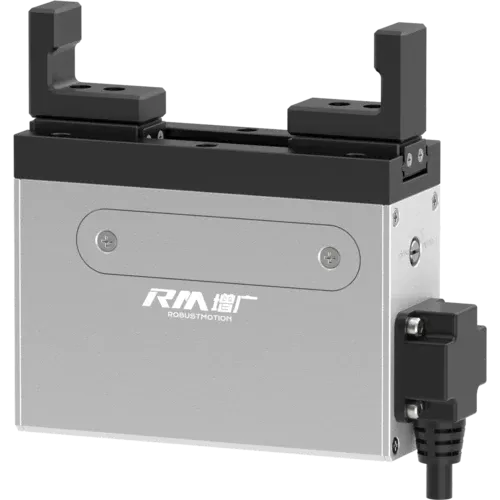
Servo Gripper (Stroke 20-40mm)
Specifications
| Model | RM-GB-11-20-2-ITG | RM-GB-11-40-2-ITG | RM-GB-11-20-2 | RM-GB-11-40-2 |
|---|---|---|---|---|
| Size Code | 11 | 11 | 11 | 11 |
| Spec | 2 | 2 | 2 | 2 |
| Weight | 0.8 kg | 1.1 kg | 0.8 kg | 1.1 kg |
| Dimensions | 105*85*36 mm | 125*85*36 mm | 105*85*36 mm | 125*85*36 mm |
| Stroke | 20 mm | 40 mm | 20 mm | 40 mm |
| Max. Gripping Force | 65 N | 110 N | 65 N | 110 N |
| Max. speed | 80 mm/s | 80 mm/s | 80 mm/s | 80 mm/s |
| Repeatability | ±0.05 mm | ±0.05 mm | ±0.05 mm | ±0.05 mm |
| Max. Open/Close Time | 0.33s / 0.33s | 0.58s / 0.58s | 0.33s / 0.33s | 0.58s / 0.58s |
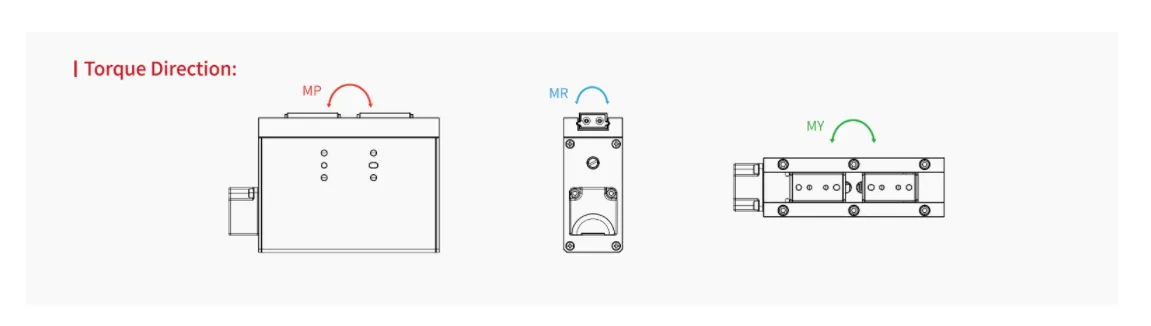
| Allowable Moment MP | 5.9 N.m | 5.9 N.m | 5.9 N.m | 5.9 N.m |
| Allowable Moment MR | 8.0 N.m | 8.0 N.m | 8.0 N.m | 8.0 N.m |
| Allowable Moment MY | 5.9 N.m | 5.9 N.m | 5.9 N.m | 5.9 N.m |
| Power-Off Self-Locking | Mechanical Self-Locking | Mechanical Self-Locking | Mechanical Self-Locking | Mechanical Self-Locking |
| Compatible Controllers | Built-in Controller | Built-in Controller | RM-C-20; RM-CEP-20; RM-CEMS-20 | RM-C-20; RM-CEP-20; RM-CEMS-20 |
| Communication Protocols | Modbus RTU; I/O | Modbus RTU; I/O | EtherCAT; Modbus TCP; PROFINET; CC-Link; Modbus RTU; I/O (See Page 75 for protocol details per controller.) | EtherCAT; Modbus TCP; PROFINET; CC-Link; Modbus RTU; I/O (See Page 75 for protocol details per controller.) |
| I/O Interface | 3 IN / 3 OUT (NPN) | 3 IN / 3 OUT (NPN) | See controller specs | See controller specs |
| Operating Voltage | DC 24V ±10% | DC 24V ±10% | DC 24V ±10% | DC 24V ±10% |
| Rated Current | 2A | 2A | 2A | 2A |
| Operating Environment | 0~40°C, < 85%RH | 0~40°C, < 85%RH | 0~40°C, < 85%RH | 0~40°C, < 85%RH |
| Protection Class | IP40 | IP40 | IP40 | IP40 |
RM-GB-17
Servo Gripper (Stroke 30-60mm)
Specifications
| Model | RM-GB-17-30-2-ITG | RM-GB-17-60-2-ITG | RM-GB-17-30-2 | RM-GB-17-60-2 |
|---|---|---|---|---|
| Size Code | 17 | 17 | 17 | 17 |
| Spec | 2 | 2 | 2 | 2 |
| Weight | 2.1 kg | 2.3 kg | 2.1 kg | 2.3 kg |
| Dimensions | 165*112*50 mm | 165*112*50 mm | 165*112*50 mm | 165*112*50 mm |
| Stroke | 30 mm | 60 mm | 30 mm | 60 mm |
| Max. Gripping Force | 350 N | 175 N | 500 N | 250 N |
| Max. speed | 80 mm/s | 80 mm/s | 80 mm/s | 80 mm/s |
| Repeatability | ±0.02 mm | ±0.05 mm | ±0.02 mm | ±0.05 mm |
| Max. Open/Close Time | 0.4s / 0.4s | 0.7s / 0.7s | 0.4s / 0.4s | 0.7s / 0.7s |
| Allowable Moment MP | 15.0 N.m | 15.0 N.m | 15.0 N.m | 15.0 N.m |
| Allowable Moment MR | 58.5 N.m | 58.5 N.m | 58.5 N.m | 58.5 N.m |
| Allowable Moment MY | 25.5 N.m | 25.5 N.m | 25.5 N.m | 25.5 N.m |
| Power-Off Self-Locking | / | Mechanical Self-Locking | Optional Brake | Mechanical Self-Locking |
| Compatible Controllers | Built-in Controller | Built-in Controller | RM-C-40; RM-CEP-40; RM-CEMS-40 | RM-C-40; RM-CEP-40; RM-CEMS-40 |
| Communication Protocols | Modbus RTU; I/O | Modbus RTU; I/O | EtherCAT; Modbus TCP; PROFINET; CC-Link; Modbus RTU; I/O (See Page 75 for protocol details per controller.) | EtherCAT; Modbus TCP; PROFINET; CC-Link; Modbus RTU; I/O (See Page 75 for protocol details per controller.) |
| I/O Interface | 3 IN / 3 OUT (NPN) | 3 IN / 3 OUT (NPN) | See controller specs | See controller specs |
| Operating Voltage | DC 24V ±10% | DC 24V ±10% | DC 24V ±10% | DC 24V ±10% |
| Rated Current | 4A | 4A | 4A | 4A |
| Operating Environment | 0~40°C, < 85%RH | 0~40°C, < 85%RH | 0~40°C, < 85%RH | 0~40°C, < 85%RH |
| Protection Class | IP40 | IP40 | IP40 | IP40 |
RM-GB-16
Servo Gripper (Stroke 80-170mm)
Specifications
| Model | RM-GB-16-80-2 | RM-GB-16-120-2 | RM-GB-16-170-2 |
|---|---|---|---|
| Size Code | 16 | 16 | 16 |
| Spec | 2 | 2 | 2 |
| Weight | 3.6 kg | 4.0 kg | 4.7 kg |
| Dimensions | 215 * 126 * 58 mm | 255 * 126 * 58 mm | 305 * 126 * 58 mm |
| Stroke | 80 mm | 120 mm | 170 mm |
| Max. Gripping Force | 600 N | 600 N | 600 N |
| Max. speed | 100 mm/s | 100 mm/s | 100 mm/s |
| Repeatability | ±0.02 mm | ±0.02 mm | ±0.02 mm |
| Max. Open/Close Time | 0.9s / 0.9s | 1.3s / 1.3s | 1.8s / 1.8s |
| Allowable Moment MP | 30 N.m | 30 N.m | 30 N.m |
| Allowable Moment MR | 60 N.m | 60 N.m | 60 N.m |
| Allowable Moment MY | 40 N.m | 40 N.m | 40 N.m |
| Power-Off Self-Locking | Optional Brake | Optional Brake | Optional Brake |
| Compatible Controllers | RM-CEU-55; RM-CEM | RM-CEU-55; RM-CEM | RM-CEU-55; RM-CEM |
| Bus Protocols | RM-CEU supports: EtherCAT; Modbus RTU; I/ORM-CEM supports: Modbus TCP; PROFINET; CC-Link | ||
| Control Interface | I/O | I/O | I/O |
| Operating Voltage | DC 24V ±10% | DC 24V ±10% | DC 24V ±10% |
| Rated Current | 6A | 6A | 6A |
| Operating Environment | 0~40°C, < 85%RH | 0~40°C, < 85%RH | 0~40°C, < 85%RH |
| Protection Class | IP40 | IP40 | IP40 |
Note: Test data measured in lab at 25°C.
Frequently Asked Questions
Q1: What is the difference between the ITG Model and the Split Type Model?
ITG model (Integrated): built-in controller within the actuator body.
Split Type Model: actuator with an external controller; a compatible controller must be selected when ordering.
Q2: How to choose between the RM-GB-ITG model and the RM-GB split type model?
- When the control method is I/O or Modbus RTU, the RM-GB-ITG model is recommended.
- When the control method is Modbus TCP or EtherCAT, the electric actuator goes with the split-type model.
Q3: What are the key features of the RM-GB Servo Gripper?
The RM-GB Servo Gripper provides high gripping force, multiple stroke options, high rigidity, power-off self-locking, and drop detection capability.
Q4: How do I select the right RM-GB Servo Gripper model for my requirements?
Please refer to the Selection Step section in the Product Catalog. For further inquiries, contact RobustMotion or an official RobustMotion distributor in your region.
Q5: Besides Modbus RTU, what communication protocols are supported?
The standard communication protocols supplied for overseas markets include I/O control, Modbus RTU, Modbus TCP, and EtherCAT. For the latest information, please contact RobustMotion or an official RobustMotion distributor in your region.
Q6: What wiring methods are available for RM-GB models?
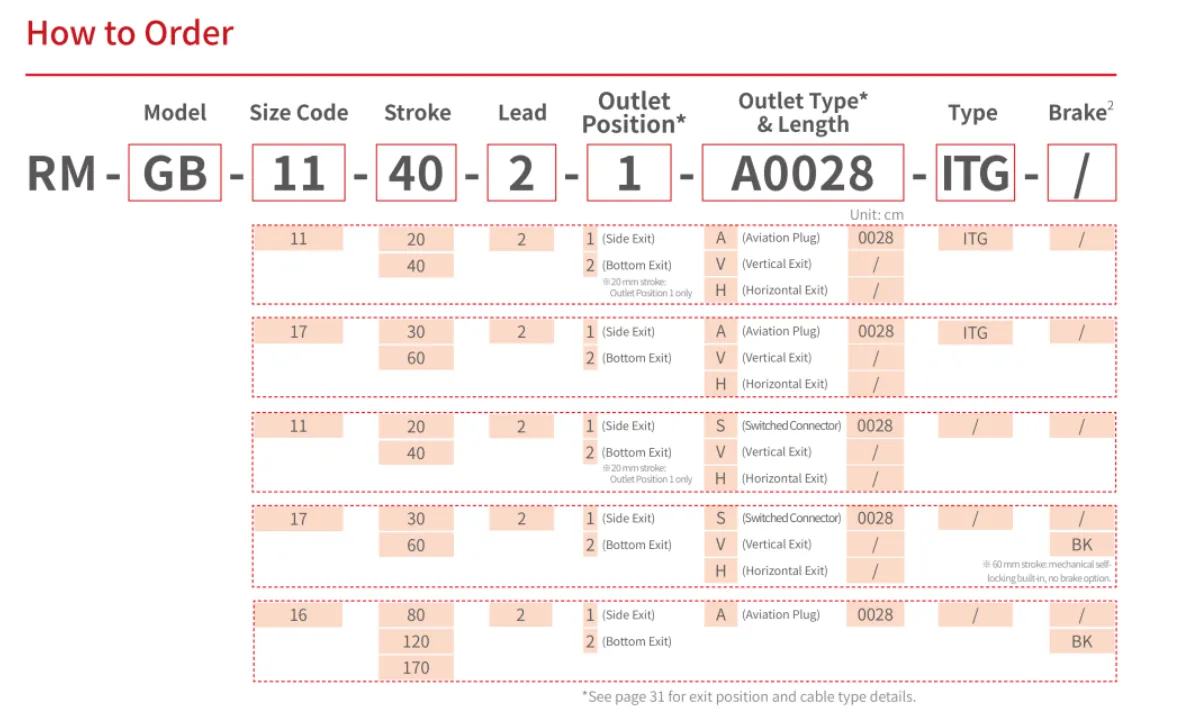
RM-GB series offers multiple wiring method options. Aviation Plug and Switched Wiring are highly recommended. Users should select and confirm depending on the specific application.
Q7: Does the RM-GB require software control?
Yes. Except for the RM-EGB series, all products require RM software-V6 Version to set motion commands.
Q8: Does the RM-GB Servo Gripper series support power-off mechanical self-lock?
Some standard RM-GB models have mechanical self-lock. For models without mechanical self-lock that require a brake function, please contact RobustMotion or an official RobustMotion distributor in your region.
Q9: How should I perform maintenance on the electric actuator?
Detailed maintenance instructions are provided in the user manual for each product.
Q10: What are the typical application industries for the RM-GB series?
The RM-GB series is widely used in 3C electronics, biomedical equipment, new energy, and automotive assembly. It supports a broad range of workpiece applications, from small electronic components to large automotive grille assemblies.
Dimension Drawings
RM-GB-11-20/40 & RM-GB-11-20/40-ITG
RM-GB-17-30/60 & RM-GB-17-30/60-ITG
3D Model Files
RM-GB-11-20-2-1-A0028-ITG
RM-GB-11-20-2-1-S0028
RM-GB-11-40-2-1-A0028-ITG
RM-GB-11-40-2-1-S0028
RM-GB-17-30-2-1-A0028-ITG
RM-GB-17-30-2-1-S0028
RM-GB-17-60-2-1-A0028-ITG
RM-GB-17-60-2-1-S0028
User'Manual
RobustMotion RM-GB Product User Manual