In industrial automation, conveyor systems are undergoing a fundamental transition from mechanical transmission to electromagnetic drive. Traditional belt, chain, and roller conveyors face persistent bottlenecks — insufficient flexibility, limited precision, and frequent maintenance. Magnetic levitation technology offers a new answer. But the term "maglev conveyor" actually encompasses two fundamentally different technical architectures: track-constrained linear magnetic drive systems and track-free planar maglev systems. Understanding the distinction is essential for any automation engineer evaluating transport technology today.
How Linear Magnetic Drive Works
A linear magnetic drive conveyor is, at its core, a multi-mover linear motor system. The principle can be visualized by imagining a rotary servo motor "unrolled" flat: the stator extends as a fixed track with embedded electromagnetic coils, while the movers (carriers) contain permanent magnet arrays. The controller energizes coils in sequence, generating a traveling magnetic wave that propels each mover along the track.
Critically, these systems retain mechanical guide rails. Movers are physically supported and guided by slides or rollers in contact with the track — magnetic force provides propulsion only, not full levitation. Motion is constrained to the track layout: loops, straight sections, merge/divert networks can be constructed, but the mover can never leave the track. In strict technical terms, most "magnetic drive conveyors" on the market are magnetic direct-drive systems, not true magnetic levitation.
How Planar Maglev Works — The MagiFloater Example
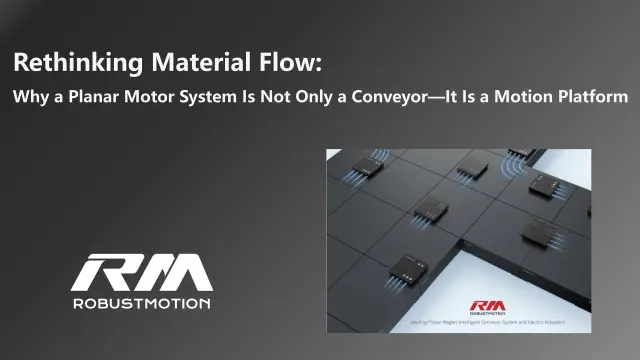
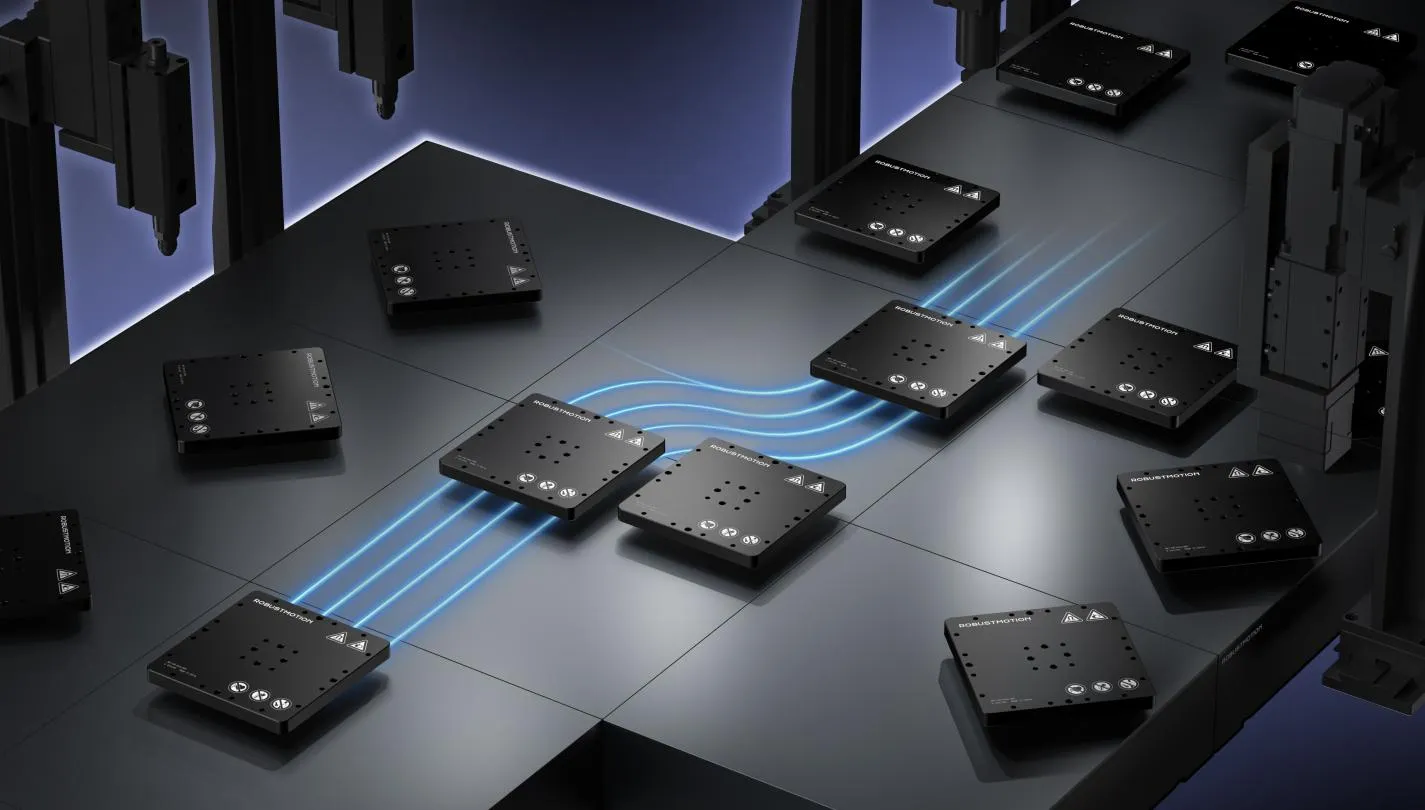
Planar magnetic levitation represents true contactless suspension technology. The system consists of modular planar motor tiles — such as the MagiFloater® platform from RobustMotion — that tessellate into working surfaces of virtually any shape and size. In other words, the entire working surface is a planar motor — the two-dimensional counterpart to a linear motor, generating force across a plane rather than along a single axis. Electromagnetic fields generated within the tile matrix produce propulsion forces in the X and Y axes simultaneously, along with a levitation force in the Z axis.
The mover floats above the surface in a controlled air gap, requiring no mechanical support whatsoever. This enables genuine six-degree-of-freedom motion: translation in X and Y, vertical adjustment in Z, plus pitch, yaw, and roll. The MagiFloater® mover can rotate, tilt, and traverse any path across the stator surface — all defined entirely in software.
This technology originates from the precision motion stages used in semiconductor lithography equipment. The control core relies on real-time decoupling of multi-dimensional electromagnetic force vectors: the system must simultaneously manage horizontal propulsion and vertical levitation, with any disturbance compensated through high-frequency closed-loop feedback. The engineering complexity is fundamentally higher than that of linear systems.
Core Performance Differences
The two architectures diverge across every engineering dimension that matters. The table below summarizes the key differences at a glance:
| Dimension | Linear Magnetic Drive | Planar Maglev (MagiFloater) |
|---|---|---|
| Motion Constraint | Along fixed track (1D or restricted 2D) | Free 2D movement + rotation/tilt (6-DOF) |
| Support Mechanism | Mechanical rails; magnetic force drives only | Full electromagnetic levitation; zero contact |
| Contamination | Reduced friction, but mechanical contact remains | Zero particulate, zero contamination |
| Layout Flexibility | Track can be modularly reassembled | Tiles arrange into any geometry; paths are software-defined |
| Mover Design | Active or passive, guided by track | Fully passive — no motors, no batteries, no cables |
| Controller Scale | Typically one controller per track segment | Single controller manages up to 256 stators |
| Cleanliness Rating | Suitable for general industrial environments | Suitable for Class 1 cleanroom and sterile applications |
Application Fit: Complementary, Not Competing
These two technologies are not substitutes; they serve different manufacturing scenarios. The table below maps each technology to its strongest application domains:
| Application Area | Linear Magnetic Drive | Planar Maglev (MagiFloater) |
|---|---|---|
| Heavy-Load Transport | Strong — tens of kg, battery modules, automotive parts | Lighter payloads, precision-focused |
| High-Speed Long-Range | Strong — up to 6 m/s, long track runs | Optimized for precision positioning, not raw speed |
| Semiconductor / Wafer Handling | Limited — mechanical contact risks contamination | Ideal — full contactless, 360° rotation, Class 1 cleanroom |
| 3C Electronics Assembly | General transport between stations | Mover as processing platform: tilt, rotate, dispense, inspect |
| Pharma & Biomedical | Suitable for bulk material transport | Ideal — sterile, per-carrier process parameter traceability |
| Food & Cosmetics | Acceptable with hygienic design | Ideal — fully washable (CIP), FDA-compliant, zero wear |
| Changeover Speed | Requires physical track reconfiguration | Software-defined path change in hours, not days |
Linear magnetic drive excels in heavy-load, high-speed, long-range transport. It has achieved commercial maturity in lithium battery manufacturing — where independent movers transport battery modules weighing tens of kilograms with controlled acceleration — and in automotive assembly, where extended maintenance intervals compared to belt or chain conveyors deliver measurable ROI.
Planar maglev, exemplified by MagiFloater, is concentrated in high-precision, ultra-clean, and flexibility-critical applications. In semiconductor manufacturing, where wafer handling between lithography, cleaning, and CMP processes demands Class 1 cleanroom compliance, the complete absence of mechanical contact eliminates the lubricant and friction-borne contamination that traditional conveyors introduce. The levitating carrier can rotate 360° in the horizontal plane, enabling multi-angle processing that no track-based system can achieve.
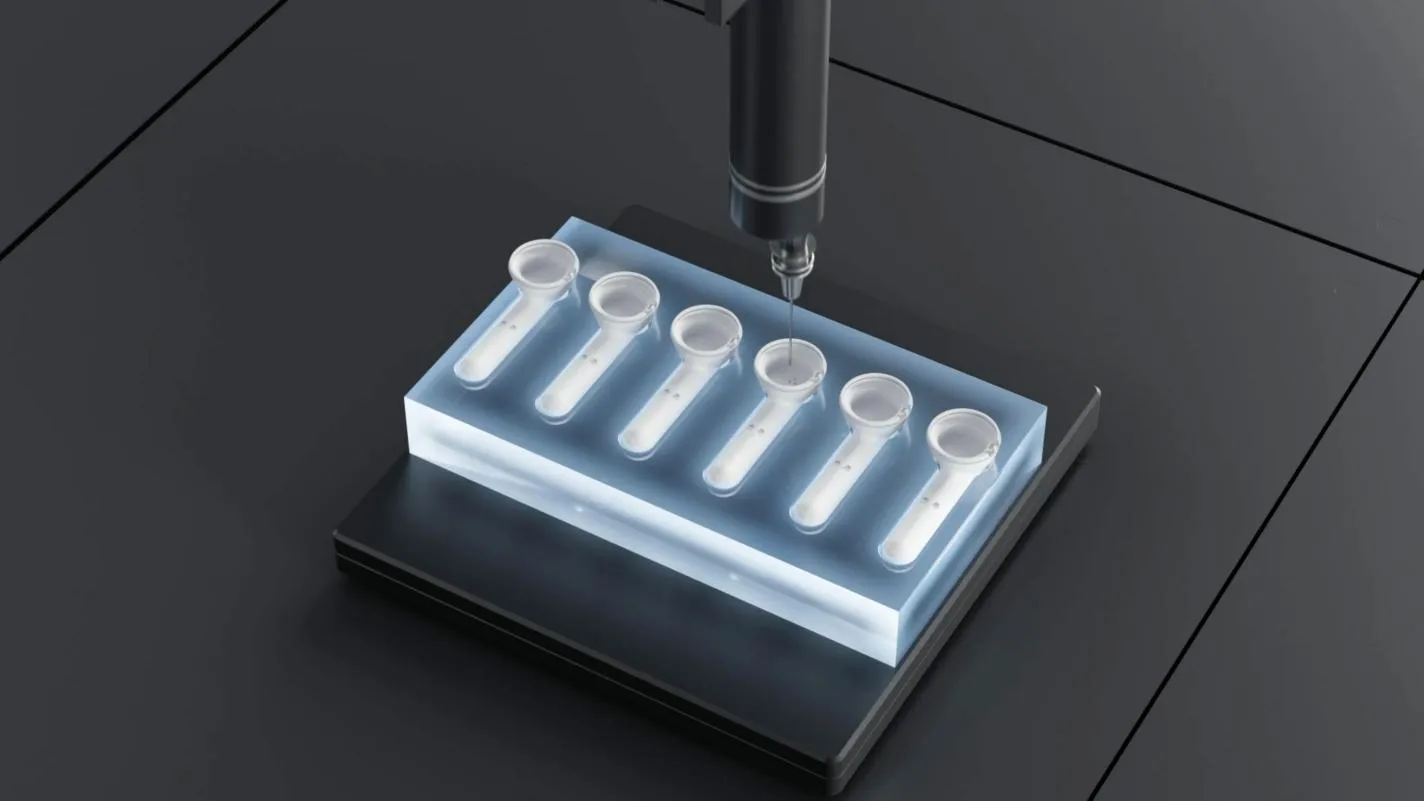
In 3C electronics assembly, the mover functions as more than a carrier — it becomes a processing platform. A single MagiFloater mover carrying a phone sub-assembly can tilt to present the workpiece to a dispensing nozzle at the optimal angle, then rotate to a vision inspection station, and reposition for press-fitting — all without transferring the product between fixtures. The boundaries between transport and process dissolve.
In biomedical and pharma applications, each levitating carrier can independently carry and record process parameters — temperature, batch information, dwell time — as it follows its software-defined path through complex multi-zone layouts, maintaining full traceability throughout.
The Bottom Line
The essence of magnetic levitation conveyor technology is replacing the rigidity of mechanical transmission with the flexibility of electromagnetic fields. Linear magnetic drive achieves flexible heavy-duty transport through "tracked magnetic direct drive" — it is the workhorse of current industrial automation. Planar maglev, powered by the planar motor's trackless six-degree-of-freedom levitation, represents the ultimate integration of transport and process — and points toward the future of flexible manufacturing.
For engineers, understanding this boundary — linear drive wins on load and speed, planar maglev wins on cleanliness, precision, and flexibility — is the foundation of sound technology selection. As the technology matures and modularizes, planar maglev systems like MagiFloater are expanding from semiconductor and medical bottleneck applications into precision electronics assembly, high-end packaging, and beyond — transitioning from a premium option into core infrastructure for smart manufacturing.